
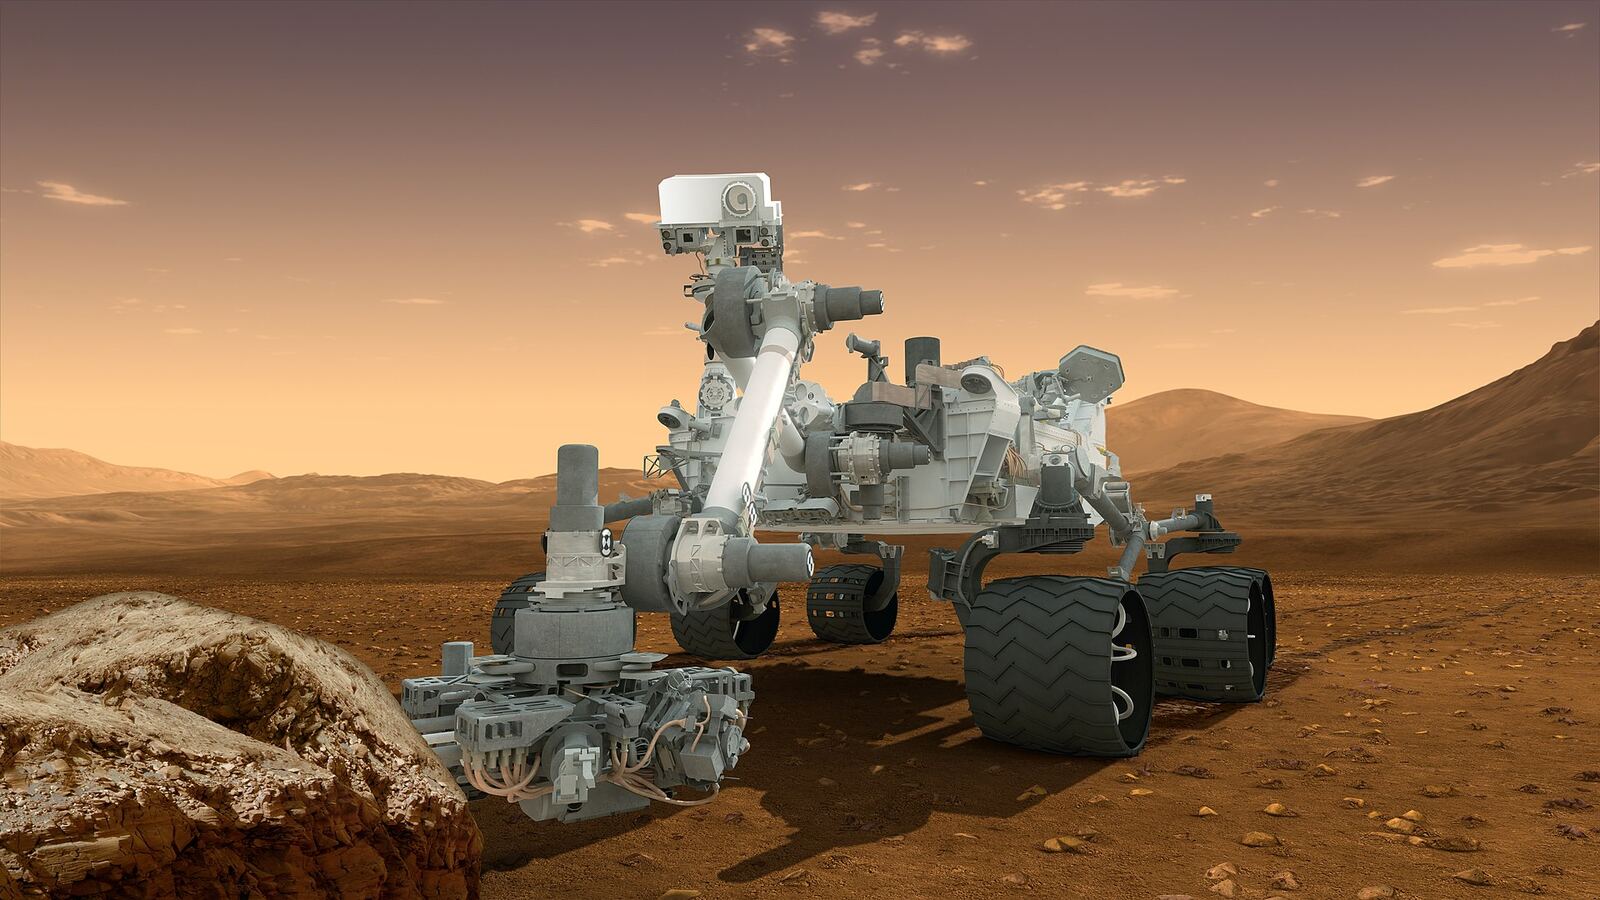
Vision for Autonomous Exploration Robots
Multimodal perception that lets robots navigate unknown terrain safely.
- computer vision
- autonomous robots
Professor and founding head of Athena Lab. Works on machine learning theory, optimization and representation learning.
AAAI 2026 - Proceedings of the 40th AAAI Conference on Artificial Intelligence
@inproceedings{pham2026localsgd,
  title     = {Convergence of Local SGD under Heterogeneous Data},
  author    = {Pham, Quoc Anh and Tran, Minh Khoa and Rossi, Elena},
  booktitle = {Proceedings of the 40th AAAI Conference on Artificial Intelligence},
  year      = {2026}
}JMLR - Journal of Machine Learning Research
@article{dang2025samplerl,
  title   = {Sample-Efficient Reinforcement Learning for Robot Manipulation},
  author  = {Dang, Hoang Nam and Tran, Minh Khoa},
  journal = {Journal of Machine Learning Research},
  volume  = {26},
  year    = {2025}
}arXiv - arXiv preprint
@misc{han2024lightweight,
  title = {Lightweight Language Models for Open Scientific Workflows},
  author = {Võ Gia Hân and Trần Minh Khoa and Priya Nair},
  howpublished = {arXiv preprint},
  year = {2024},
  url = {https://arxiv.org/abs/2402.00004}
}TMLR - Transactions on Machine Learning Research
@article{khoa2023spectral,
  title = {A Spectral View of Attention: Rank Collapse and Remedies},
  author = {Trần Minh Khoa and Đặng Hoàng Nam and Lukas Meier},
  journal = {Transactions on Machine Learning Research},
  year = {2023},
  url = {https://doi.org/10.0000/example.tmlr.2023.07}
}Multimodal perception that lets robots navigate unknown terrain safely.
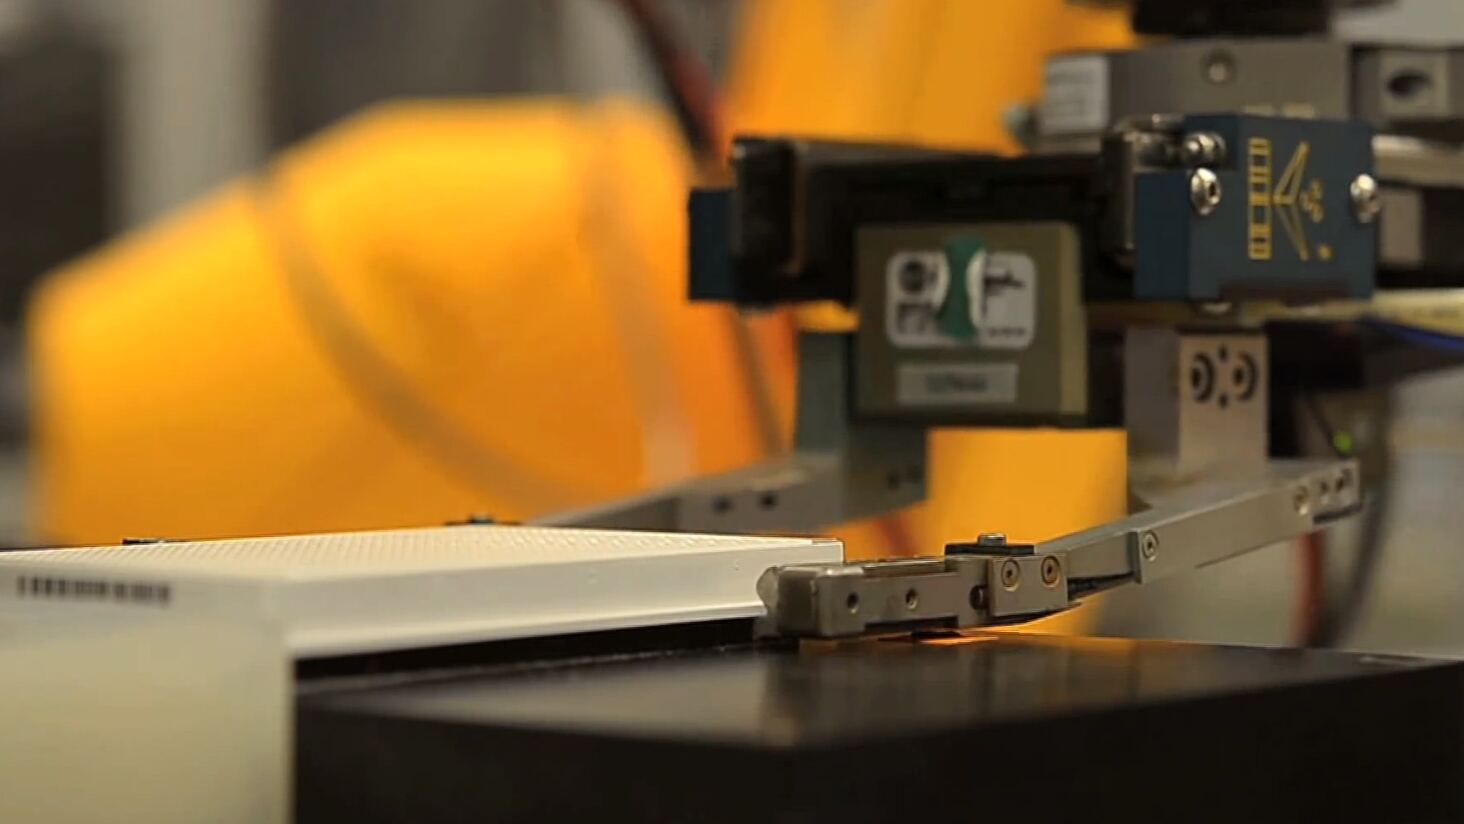
Sample-efficient reinforcement learning for robot arms handling lab samples.
Open-source tools and small language models for reproducible research.
New convergence results for Local SGD under heterogeneous data.
Group seminar on convergence bounds for SGD with non-convex objectives.
A new master student joins the Open Science Toolkit project.
Luận án về học tăng cường hiệu quả dữ liệu cho điều khiển robot.
Mở đăng ký cho các hướng học máy, thị giác máy tính và robot.
The Example Open Science Fund supports the project for two years.