
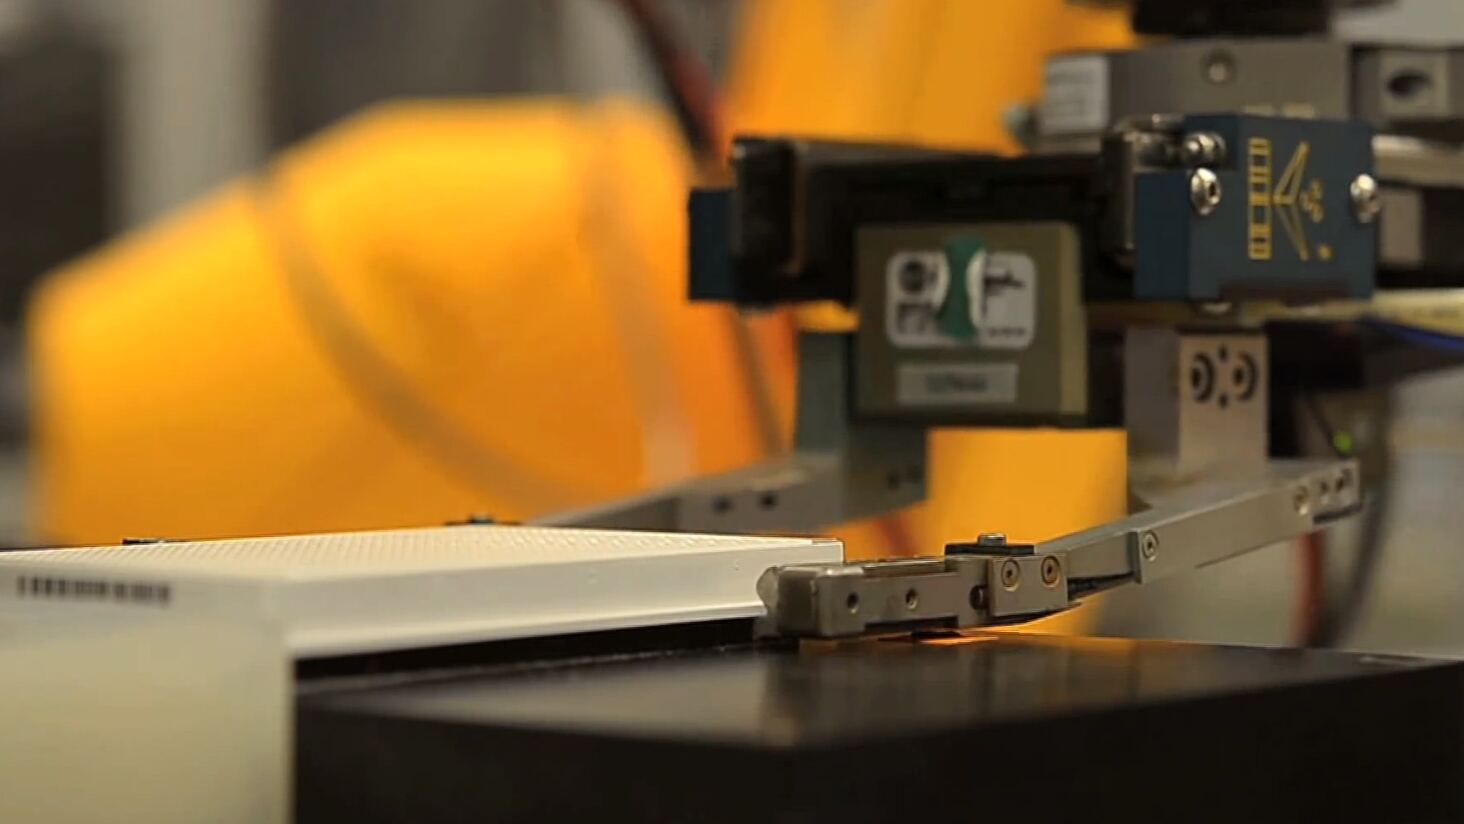
Laboratory Automation Robotics
Sample-efficient reinforcement learning for robot arms handling lab samples.
- reinforcement learning
- robotics
PhD, former PhD student
PhD students · Joined 2020
Graduated 2026 · Now at Phòng thí nghiệm Robot Mẫu, Đại học Ví Dụ
Defended his PhD in 2026 on sample-efficient reinforcement learning for robot control.
JMLR - Journal of Machine Learning Research
@article{dang2025samplerl,
  title   = {Sample-Efficient Reinforcement Learning for Robot Manipulation},
  author  = {Dang, Hoang Nam and Tran, Minh Khoa},
  journal = {Journal of Machine Learning Research},
  volume  = {26},
  year    = {2025}
}TMLR - Transactions on Machine Learning Research
@article{khoa2023spectral,
  title = {A Spectral View of Attention: Rank Collapse and Remedies},
  author = {Trần Minh Khoa and Đặng Hoàng Nam and Lukas Meier},
  journal = {Transactions on Machine Learning Research},
  year = {2023},
  url = {https://doi.org/10.0000/example.tmlr.2023.07}
}Sample-efficient reinforcement learning for robot arms handling lab samples.
Luận án về học tăng cường hiệu quả dữ liệu cho điều khiển robot.