
Vision for Autonomous Exploration Robots
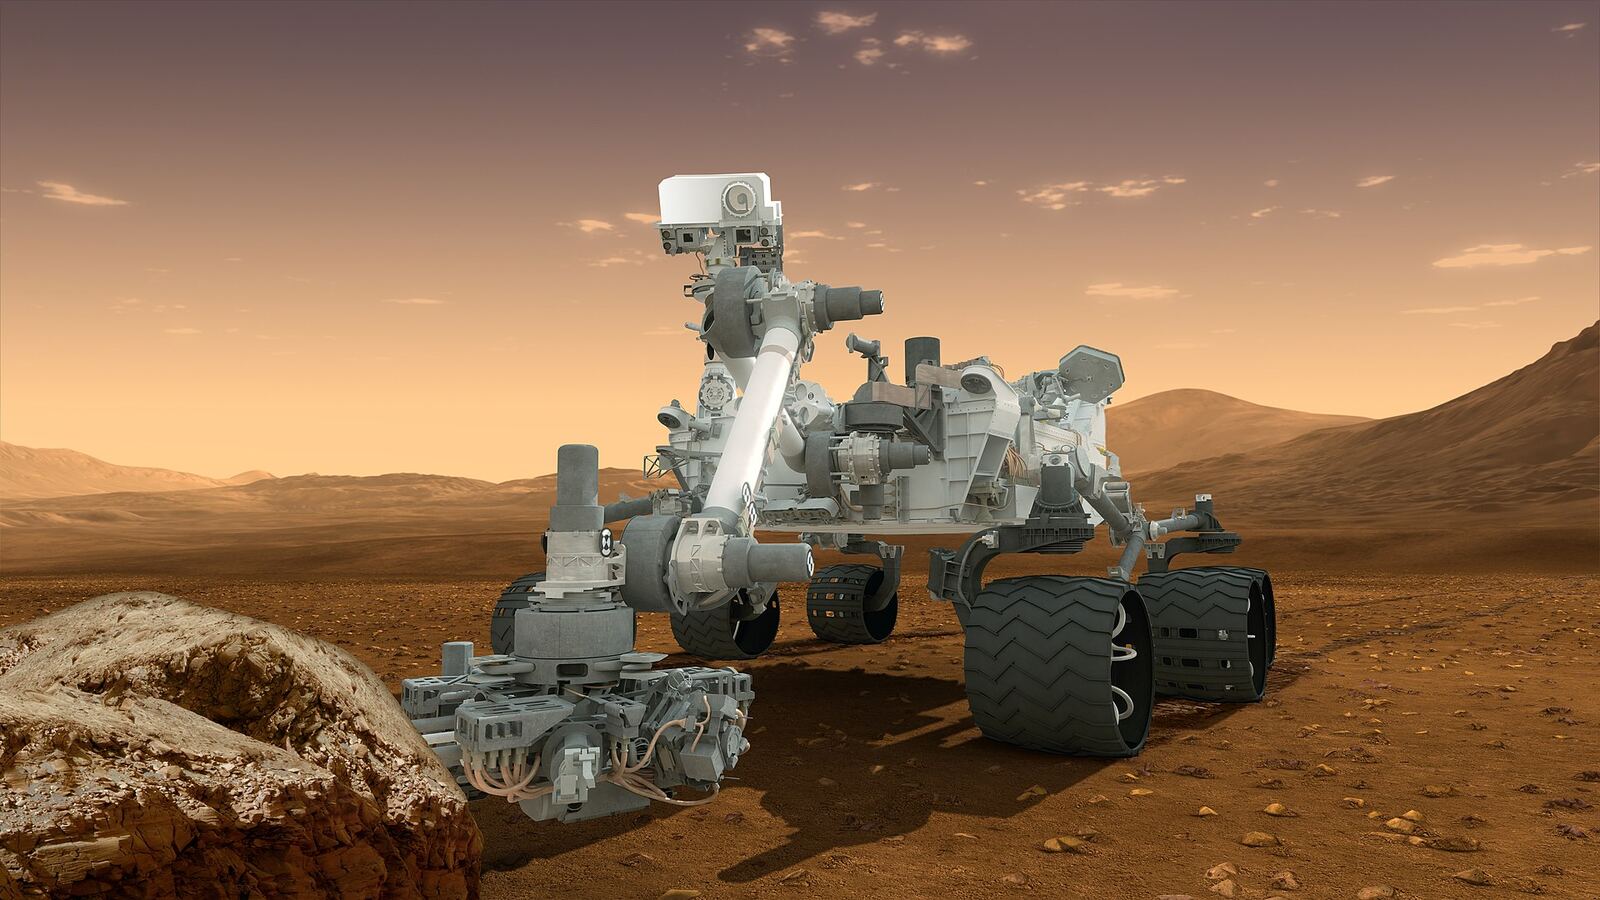
Multimodal perception that lets robots navigate unknown terrain safely.
- computer vision
- autonomous robots
PhD student working on self-supervised representation learning for robot vision.
CVPRW 2025 - IEEE/CVF Conference on Computer Vision and Pattern Recognition Workshops
@inproceedings{chau2025selfsupervised,
  title = {Self-Supervised Depth Estimation for Planetary Terrain},
  author = {Nguyễn Bảo Châu and Lê Thu Hà and Marco Bianchi},
  booktitle = {IEEE/CVF Conference on Computer Vision and Pattern Recognition Workshops},
  year = {2025},
  url = {https://arxiv.org/abs/2507.00002}
}CoRL 2024 - Conference on Robot Learning
@inproceedings{ha2024multimodal,
  title = {Multimodal Grounding of Natural-Language Instructions for Mobile Robots},
  author = {Lê Thu Hà and Nguyễn Bảo Châu and Kenji Watanabe},
  booktitle = {Conference on Robot Learning},
  year = {2024},
  url = {https://arxiv.org/abs/2411.00003}
}Multimodal perception that lets robots navigate unknown terrain safely.