
Thị giác cho robot thám hiểm tự hành
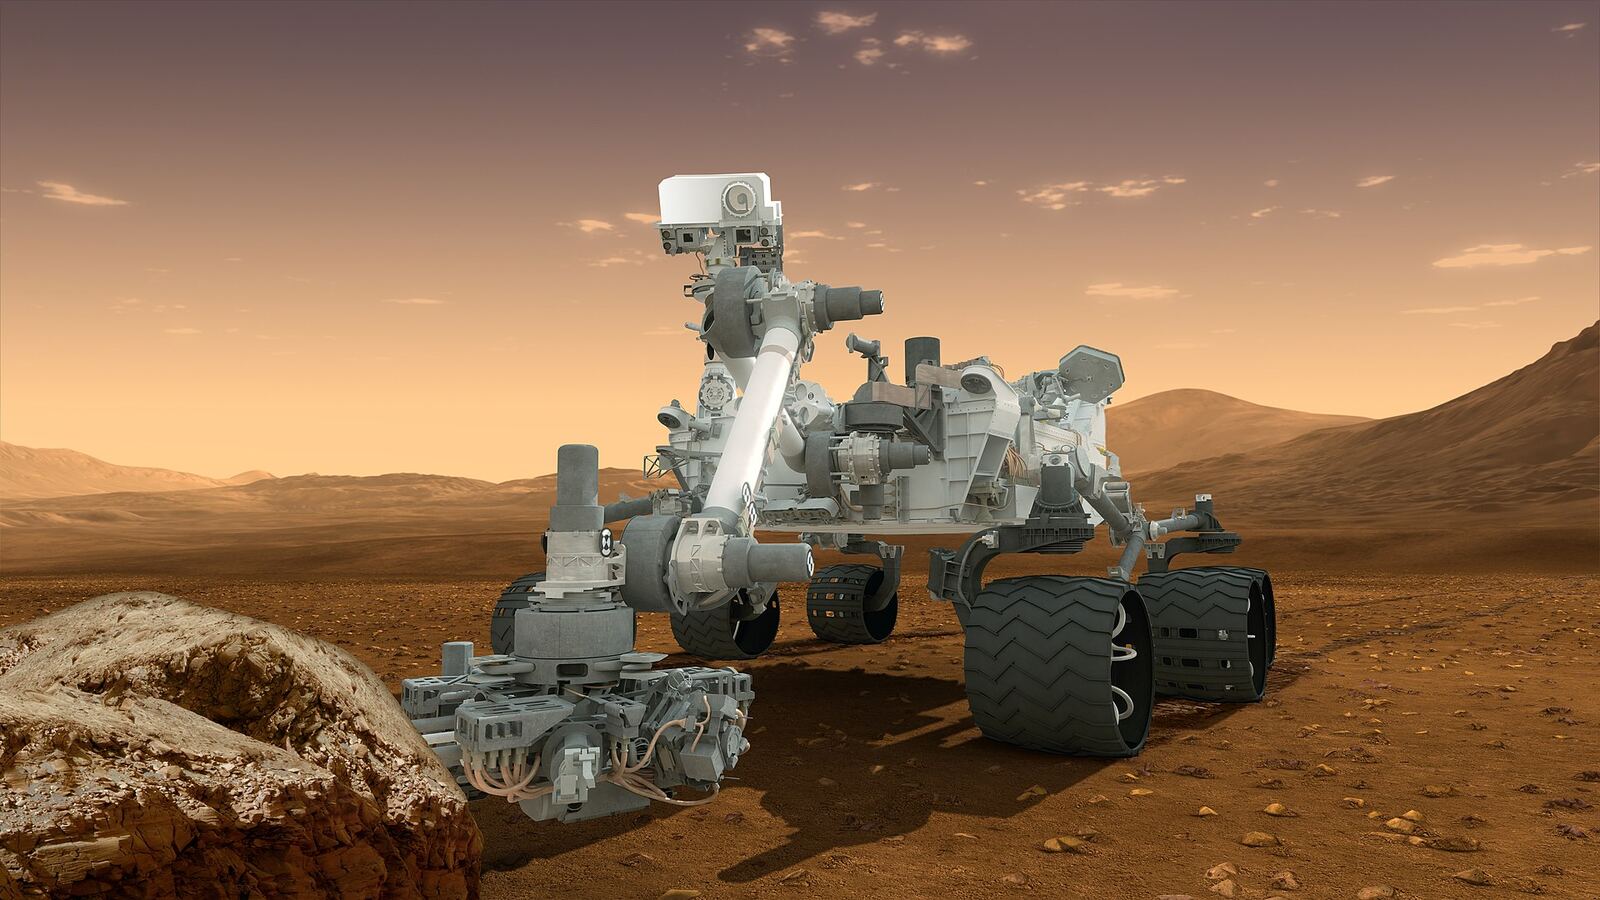
Nhận thức đa phương thức giúp robot di chuyển an toàn trên địa hình chưa biết.
- thị giác máy tính
- robot tự hành
Thu Hà bảo vệ luận án tiến sĩ năm 2023 và tham gia nhóm với vai trò nghiên cứu viên sau tiến sĩ. Chị phụ trách hướng nhận thức đa phương thức cho robot tự hành.
CVPRW 2025 - IEEE/CVF Conference on Computer Vision and Pattern Recognition Workshops
@inproceedings{chau2025selfsupervised,
  title = {Self-Supervised Depth Estimation for Planetary Terrain},
  author = {Nguyễn Bảo Châu and Lê Thu Hà and Marco Bianchi},
  booktitle = {IEEE/CVF Conference on Computer Vision and Pattern Recognition Workshops},
  year = {2025},
  url = {https://arxiv.org/abs/2507.00002}
}CoRL 2024 - Conference on Robot Learning
@inproceedings{ha2024multimodal,
  title = {Multimodal Grounding of Natural-Language Instructions for Mobile Robots},
  author = {Lê Thu Hà and Nguyễn Bảo Châu and Kenji Watanabe},
  booktitle = {Conference on Robot Learning},
  year = {2024},
  url = {https://arxiv.org/abs/2411.00003}
}Nhận thức đa phương thức giúp robot di chuyển an toàn trên địa hình chưa biết.